
Simple Stewart Platform Simulation
A Unity simulation of a Stewart platform, using kinematics to estimate platform position and orientation from actuator lengths.
Project Overview
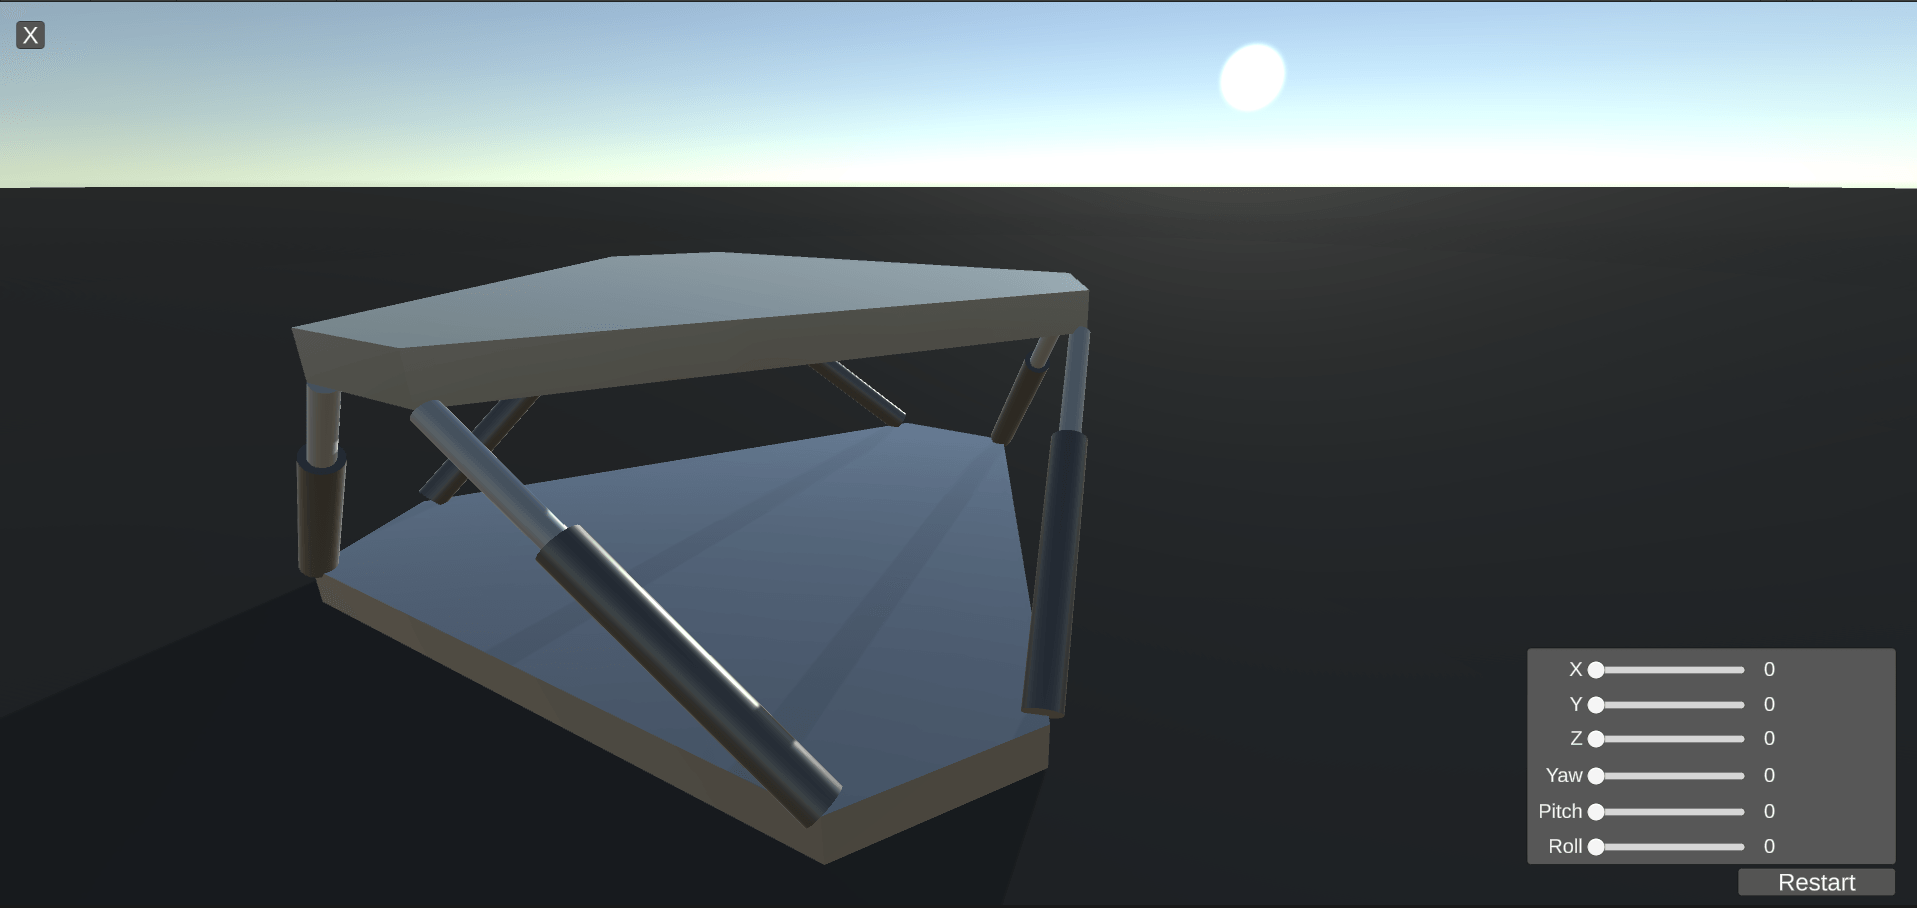
A Stewart platform (also known as a hexapod or 6-DOF platform) is a parallel robot that uses six adjustable actuators to control the position and orientation of a top plate. This project implements the simplest version of that concept in the Unity engine, using kinematics to estimate the platform’s position from its actuator lengths.
Technical Details
- Built in Unity using C# for the kinematics logic and ShaderLab/HLSL for platform visuals.
- Simulates the geometric relationship between the six linear actuators and the resulting plate position/orientation, with a small margin of error.