
Servo Tester
A dedicated hardware debugging tool that measures servo angle accuracy against a potentiometer reference to catch factory calibration defects.
Project Overview
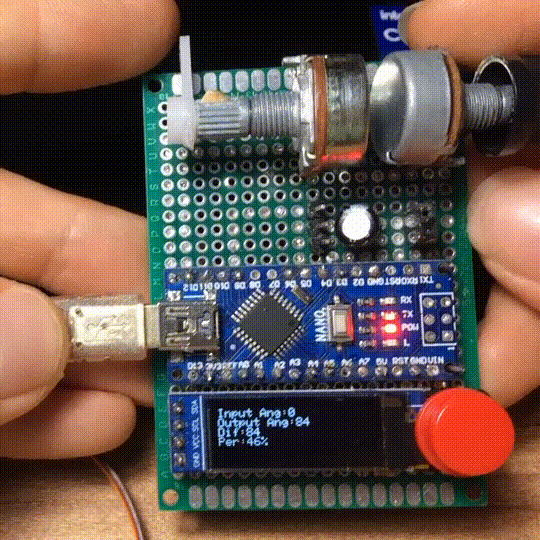
Cheap hobby servos like the SG90 and MG90 don’t always turn to the exact angle they’re commanded to — a factory defect that throws off kinematics calculations on robots like my Quadruped Spider Robot. This tester measures that error directly: a reference potentiometer sets a target angle, the servo is driven to match it, and a second potentiometer attached to the servo horn reports the actual angle achieved.
Technical Details
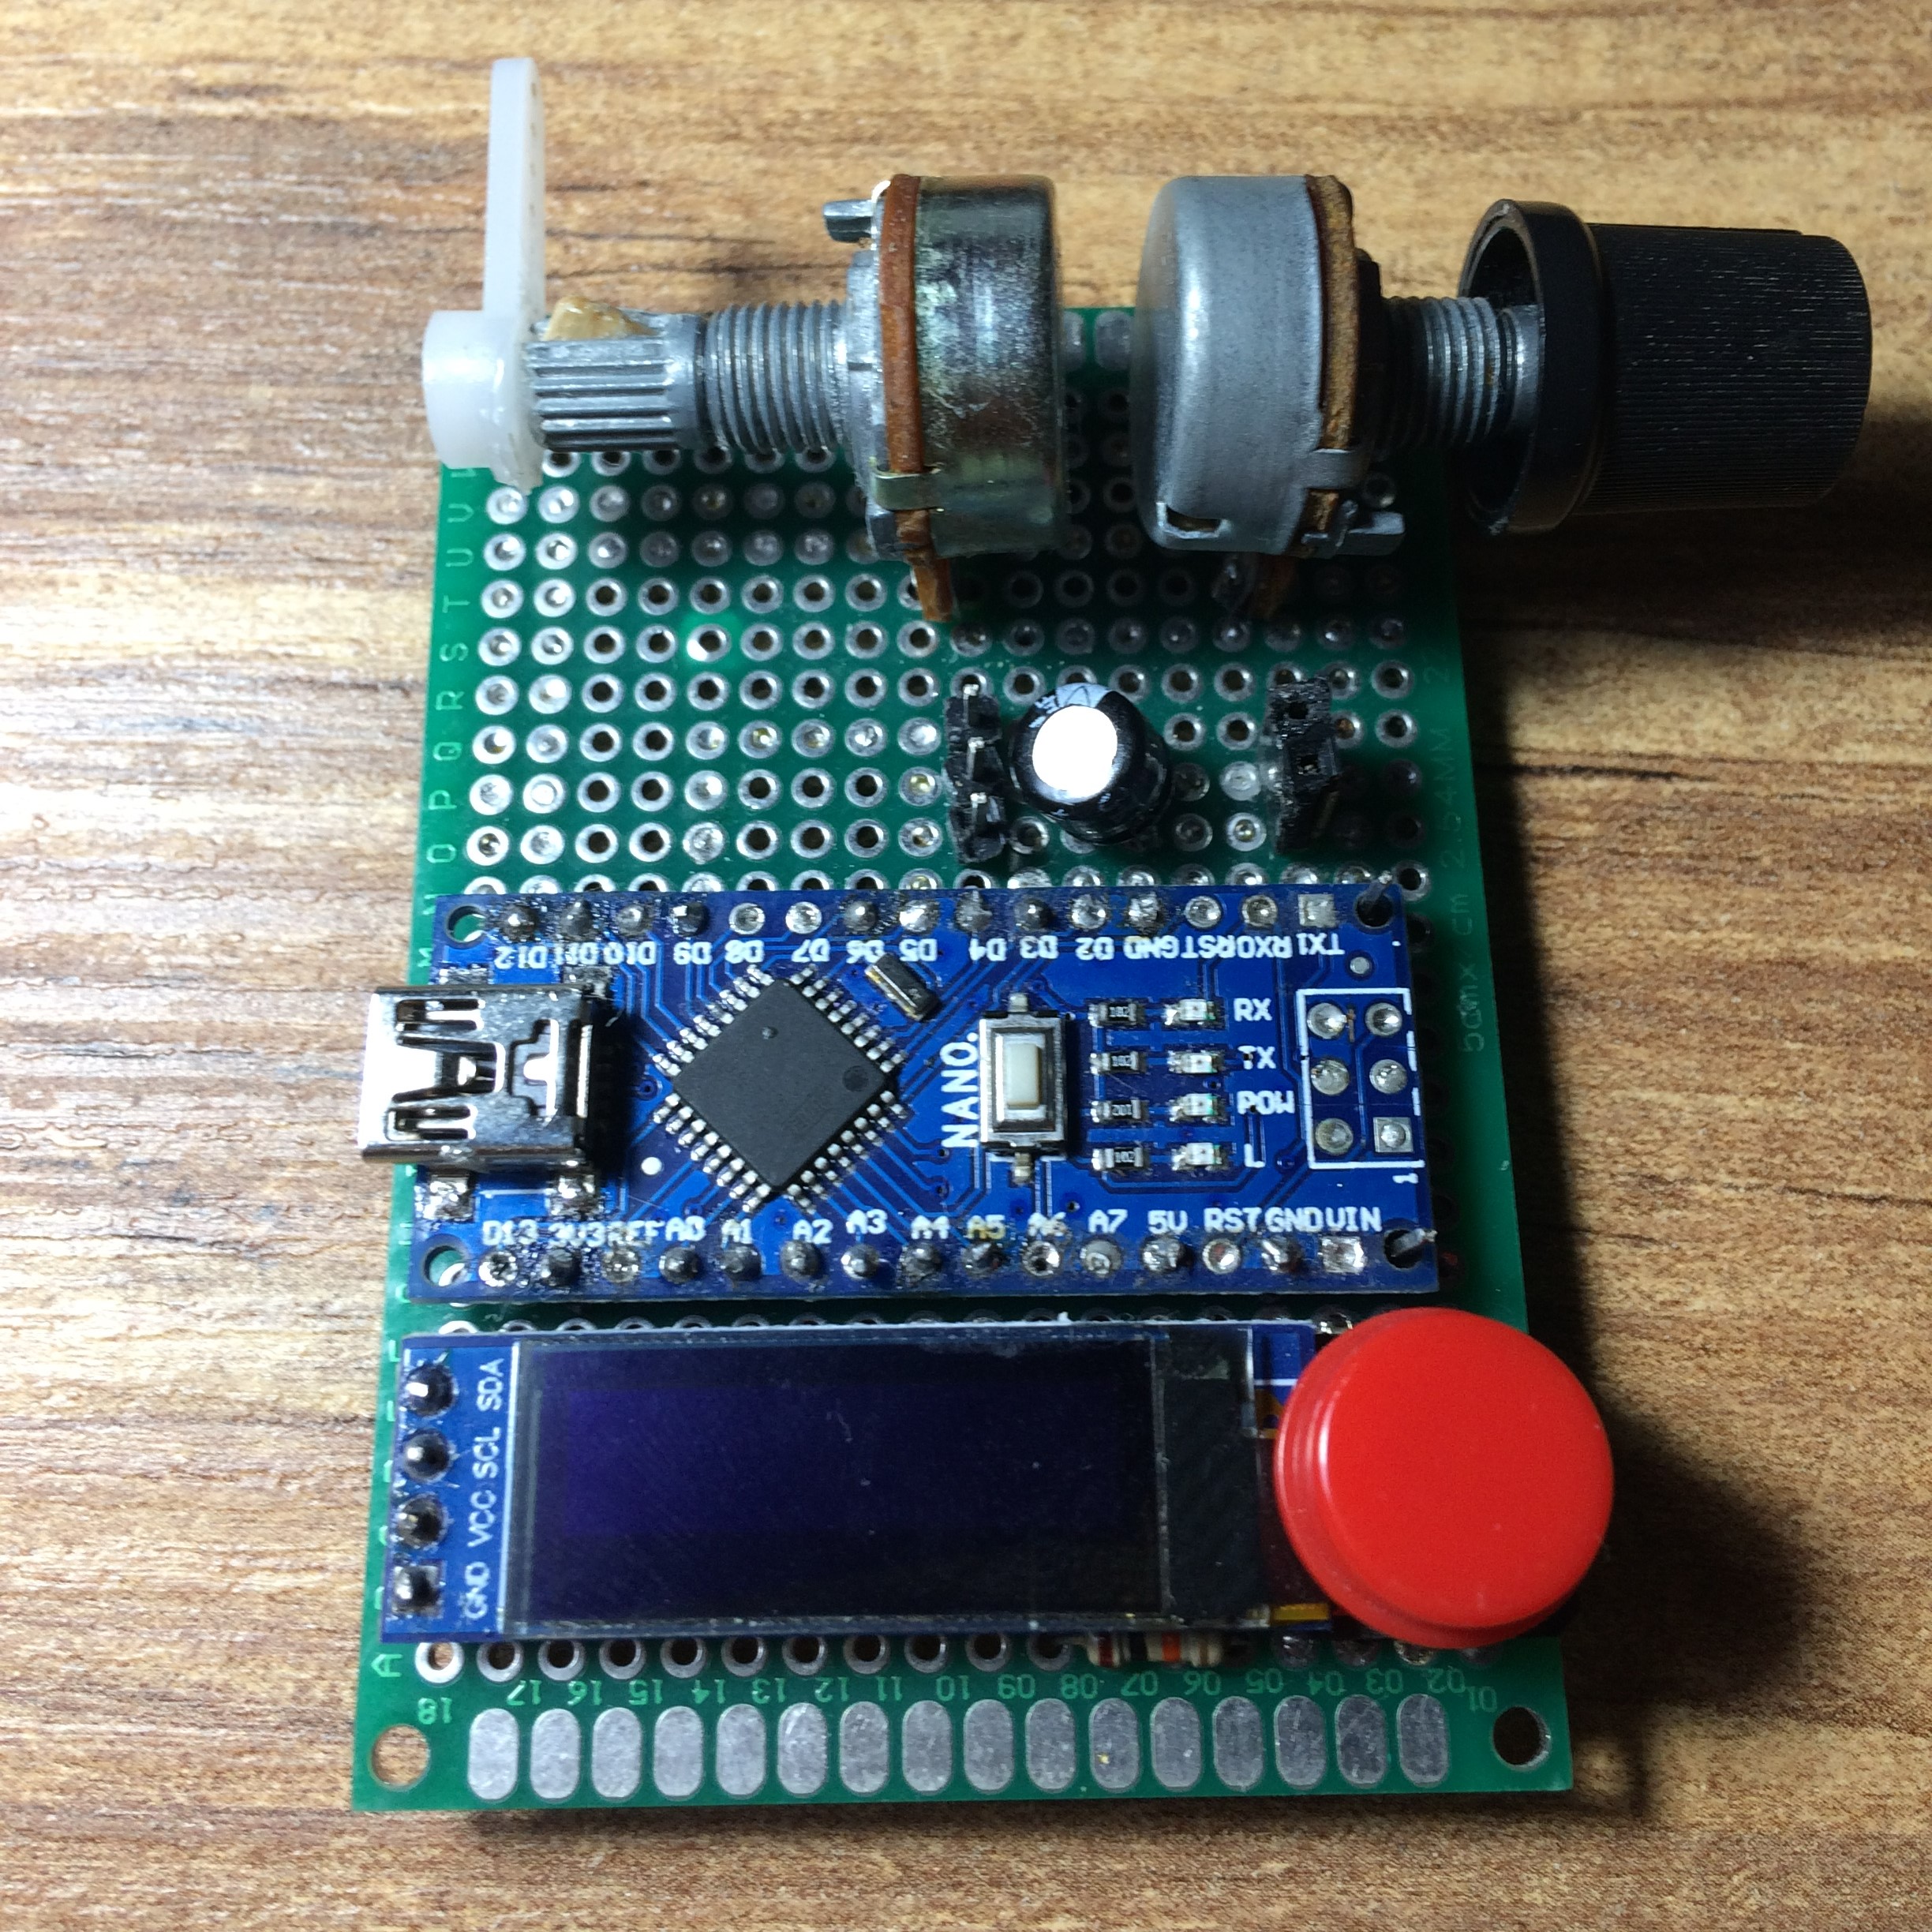
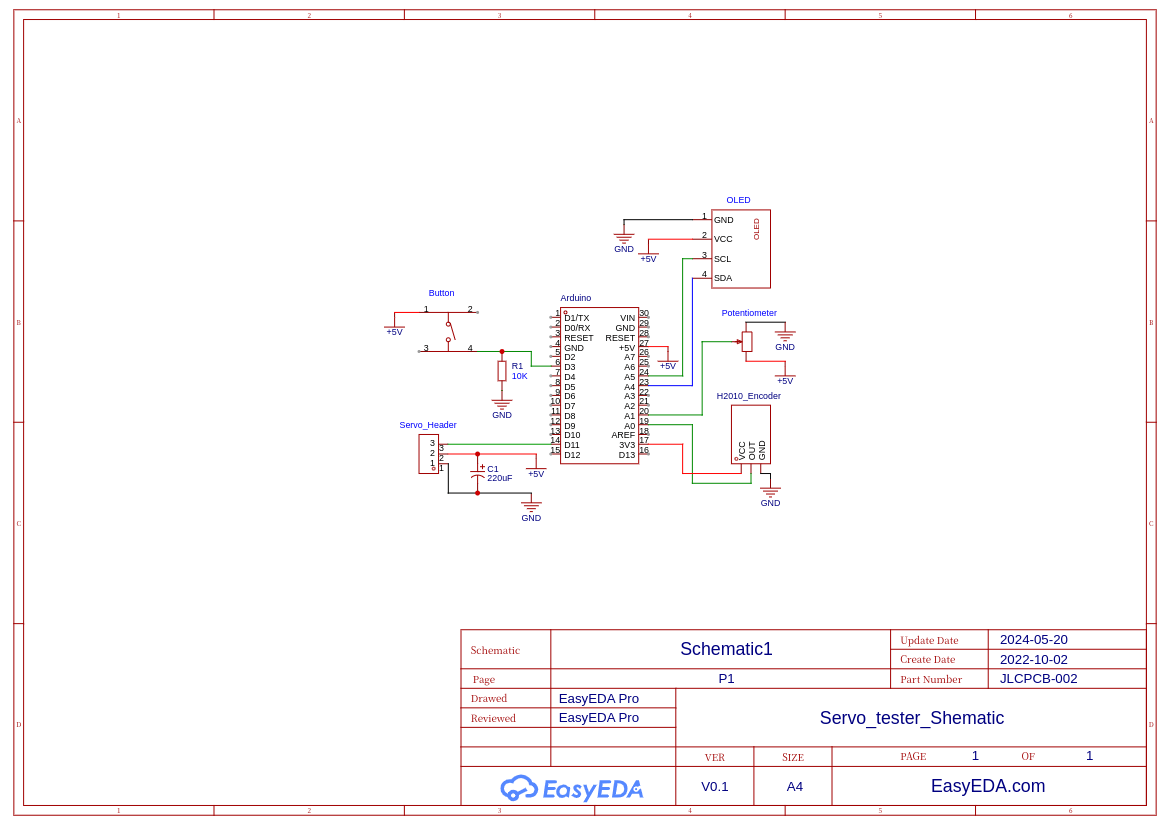
- Built around an Arduino Nano with a 128x32 OLED display for live angle readout.
- Two 10k potentiometers (reference input and servo feedback), a push button, and a 220µF capacitor for power smoothing.
- 3D-printed attachment jig, glued to the servo horn after zeroing the potentiometer to its default position.
Conclusion
Measuring servo error with a potentiometer is imperfect — the attachment point introduces its own small deviation, and results only hold at constant voltage — but the tool still significantly sped up debugging on the quadruped robot.