
Quadruped Spider Robot
A four-legged walking robot built from scratch, evolving from an Arduino RC prototype to a Raspberry Pi Pico-driven platform with inverse kinematics.
Project Overview
This was my first robotics project, started in November 2020: a four-legged (quadruped) robot designed, wired, and coded entirely from scratch, using trigonometry and kinematics to translate leg-angle math into coordinated walking gaits.
V1 – Arduino Prototype | V2 – Raspberry Pi Pico
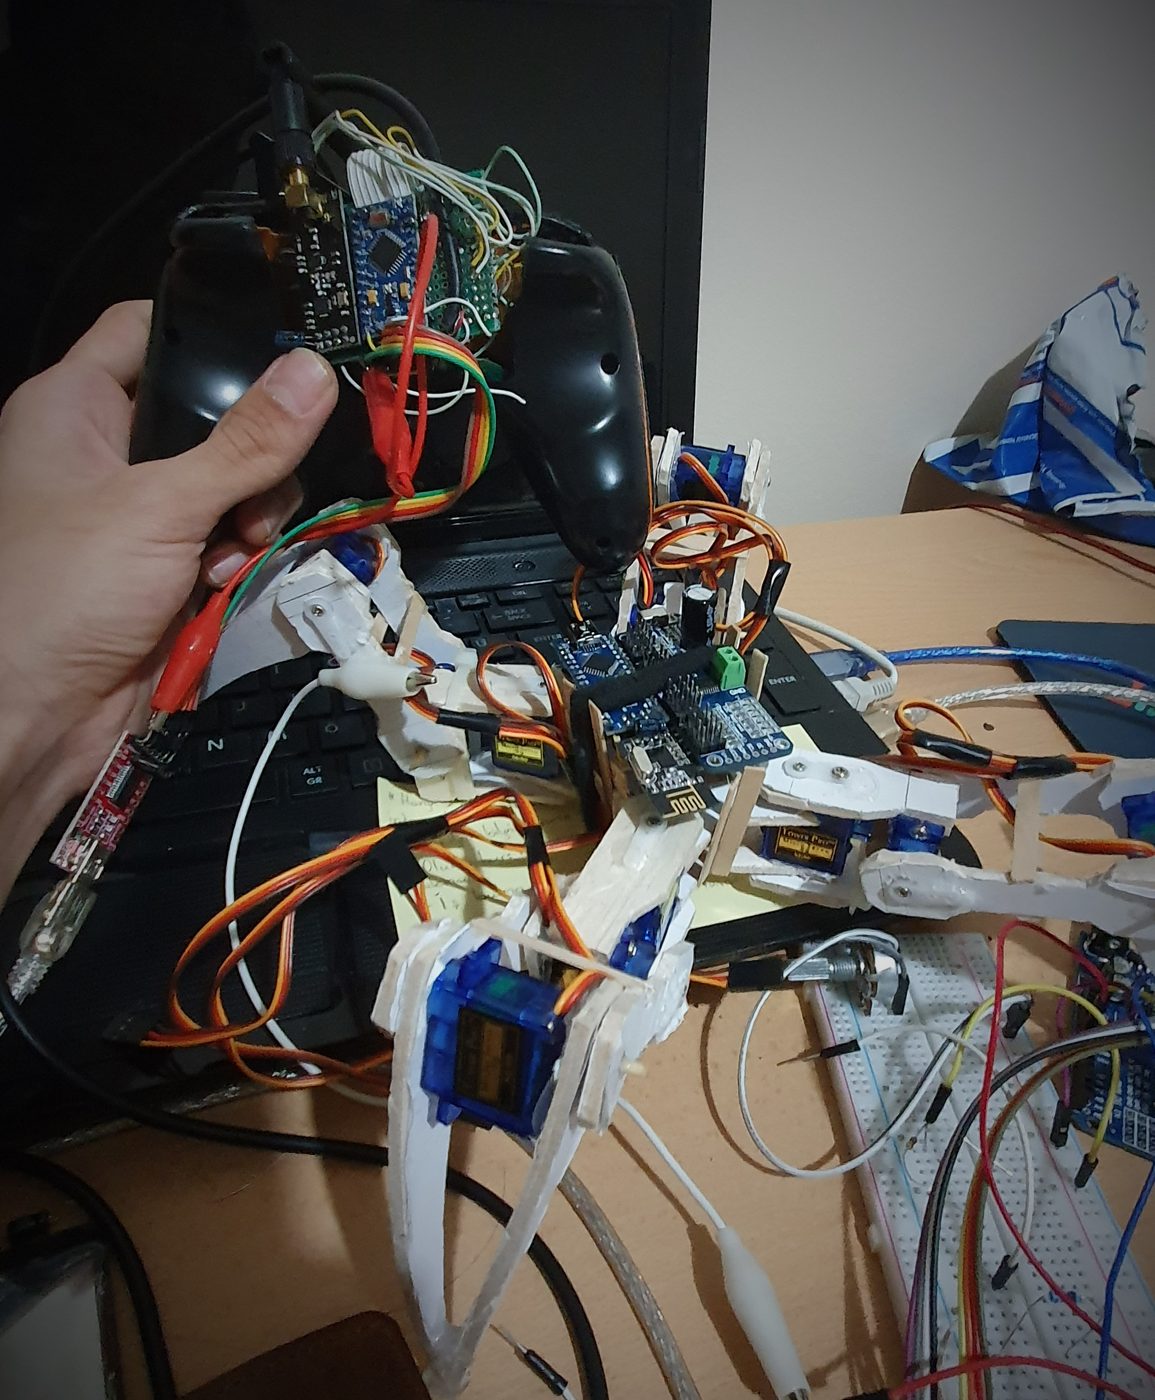
V1: Arduino RC Prototype
The first version ran on an Arduino with a 16-channel PWM servo driver, an nRF24L01 radio module for RC communication, and an 18650 Li-ion battery. It focused on validating wiring, RC communication, and basic body/leg motion functions such as walking and posing.
V2: Raspberry Pi Pico Upgrade
As the project’s computational needs grew, I moved the “brain” from Arduino to a Raspberry Pi Pico for significantly more processing headroom, adding an MPU6050 gyroscope for orientation sensing and driving 12 SG90 servo motors across the four legs, still communicating over nRF24L01.
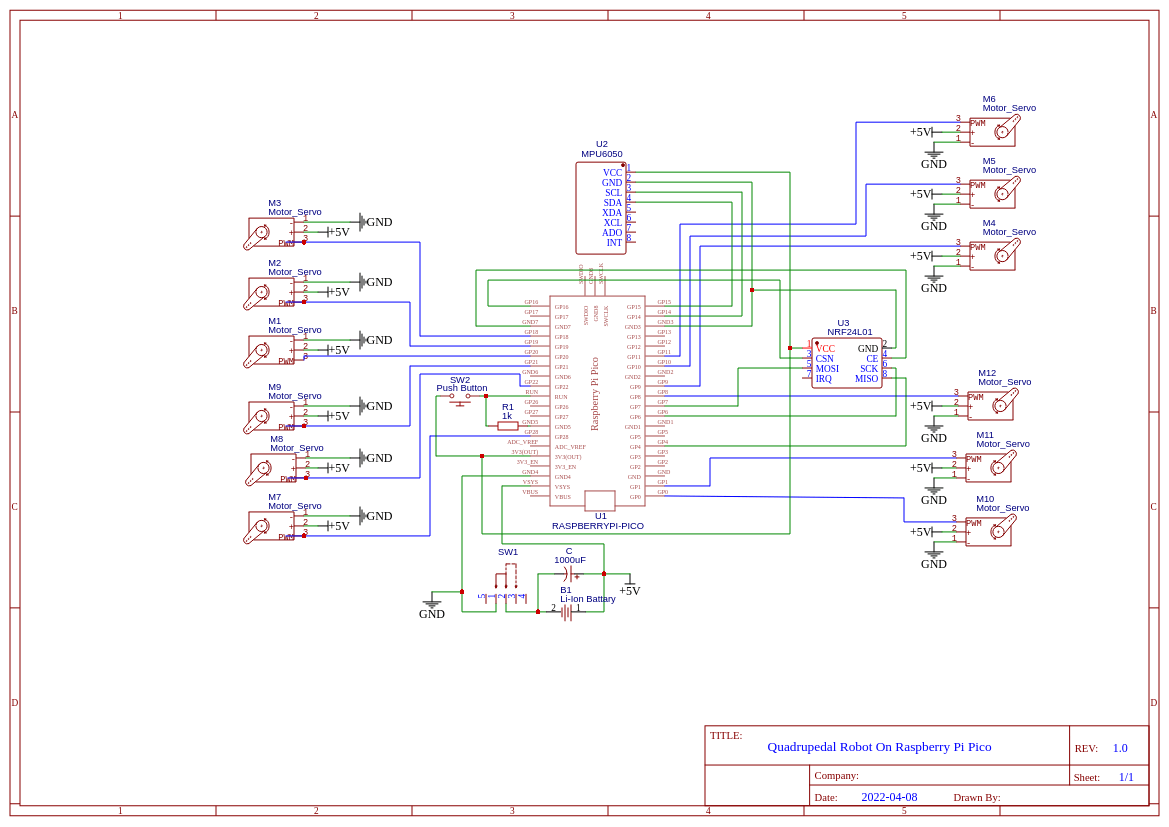
Technical Details
- Trigonometry and inverse kinematics were used to compute leg positions for stable multi-legged locomotion.
- Custom PCB and protoboard wiring for power distribution and servo control.
- Supporting tools, like a dedicated Servo Tester, were built alongside the robot to debug servo calibration issues.
What Came Next
This lineage continued into a third generation, the ROS2-based Quadruped Robot, which rebuilt the same walking-robot problem around ROS2’s node architecture on a Raspberry Pi Zero 2W.